Integrated Hand Data-Acquisition Gloves
MOXIAN MATRIX gloves combine high-density tactile sensing with 6-DOF spatial positioning — capturing grasp and interaction forces for robot teleoperation, HRI research, dexterous manipulation, and embodied-AI data collection.
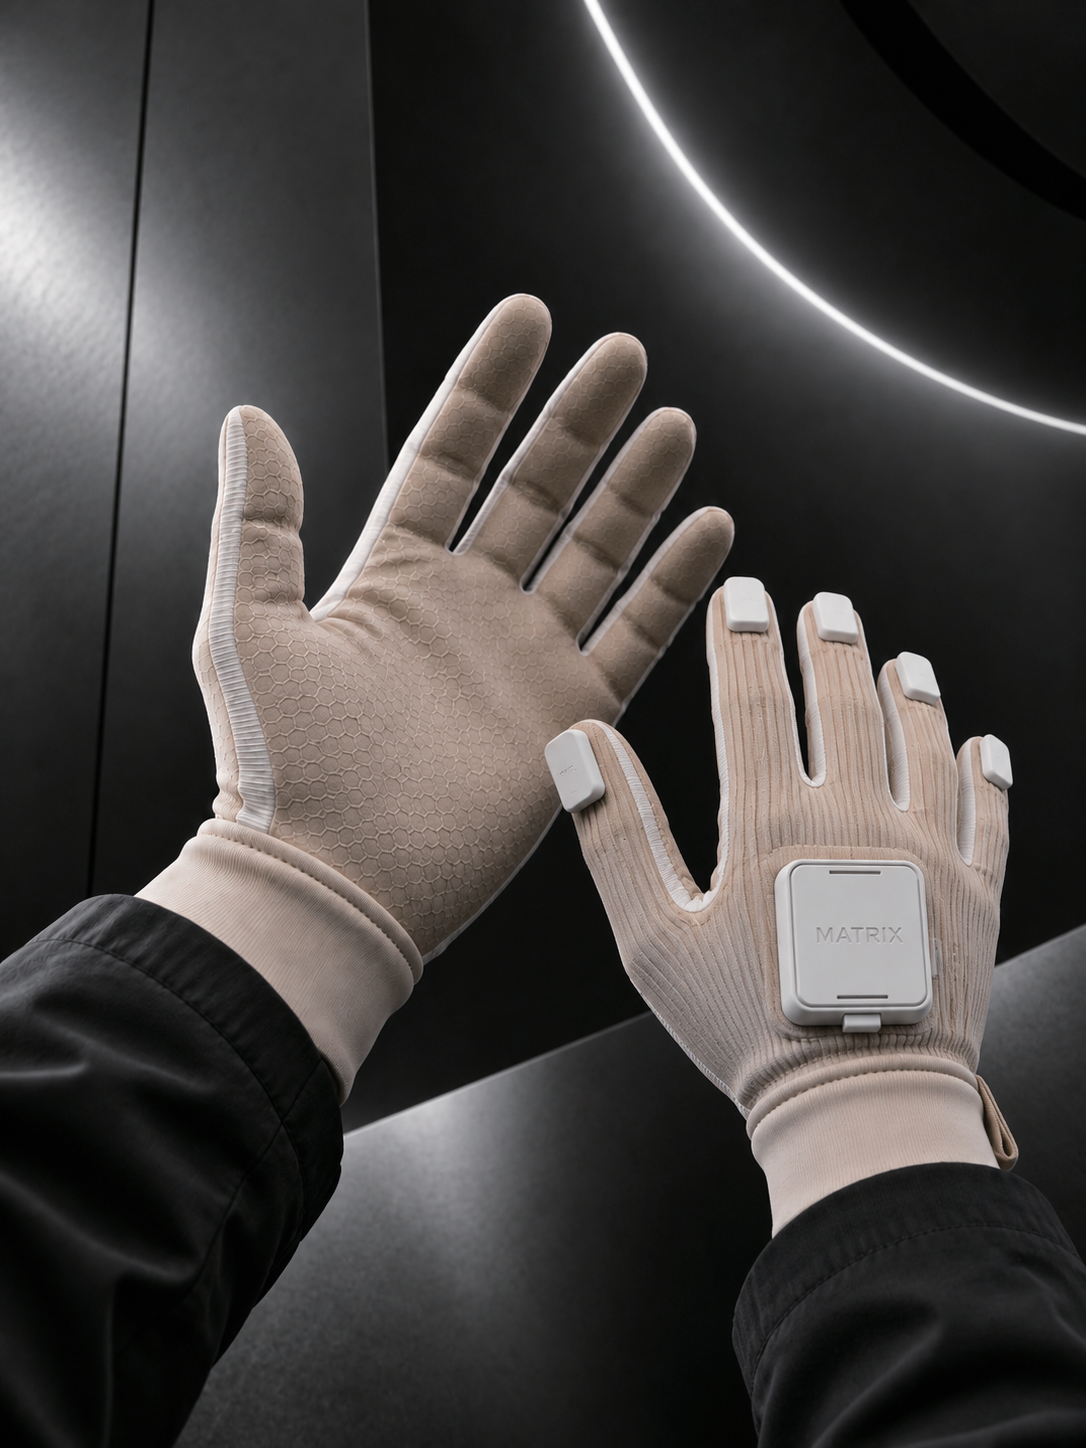 FPC TACTILE GLOVE
C-Film S1 + EMF
842 sensing points · 2 mm resolution · 0.1 N trigger · 0–20 N range · 120 Hz
View product →
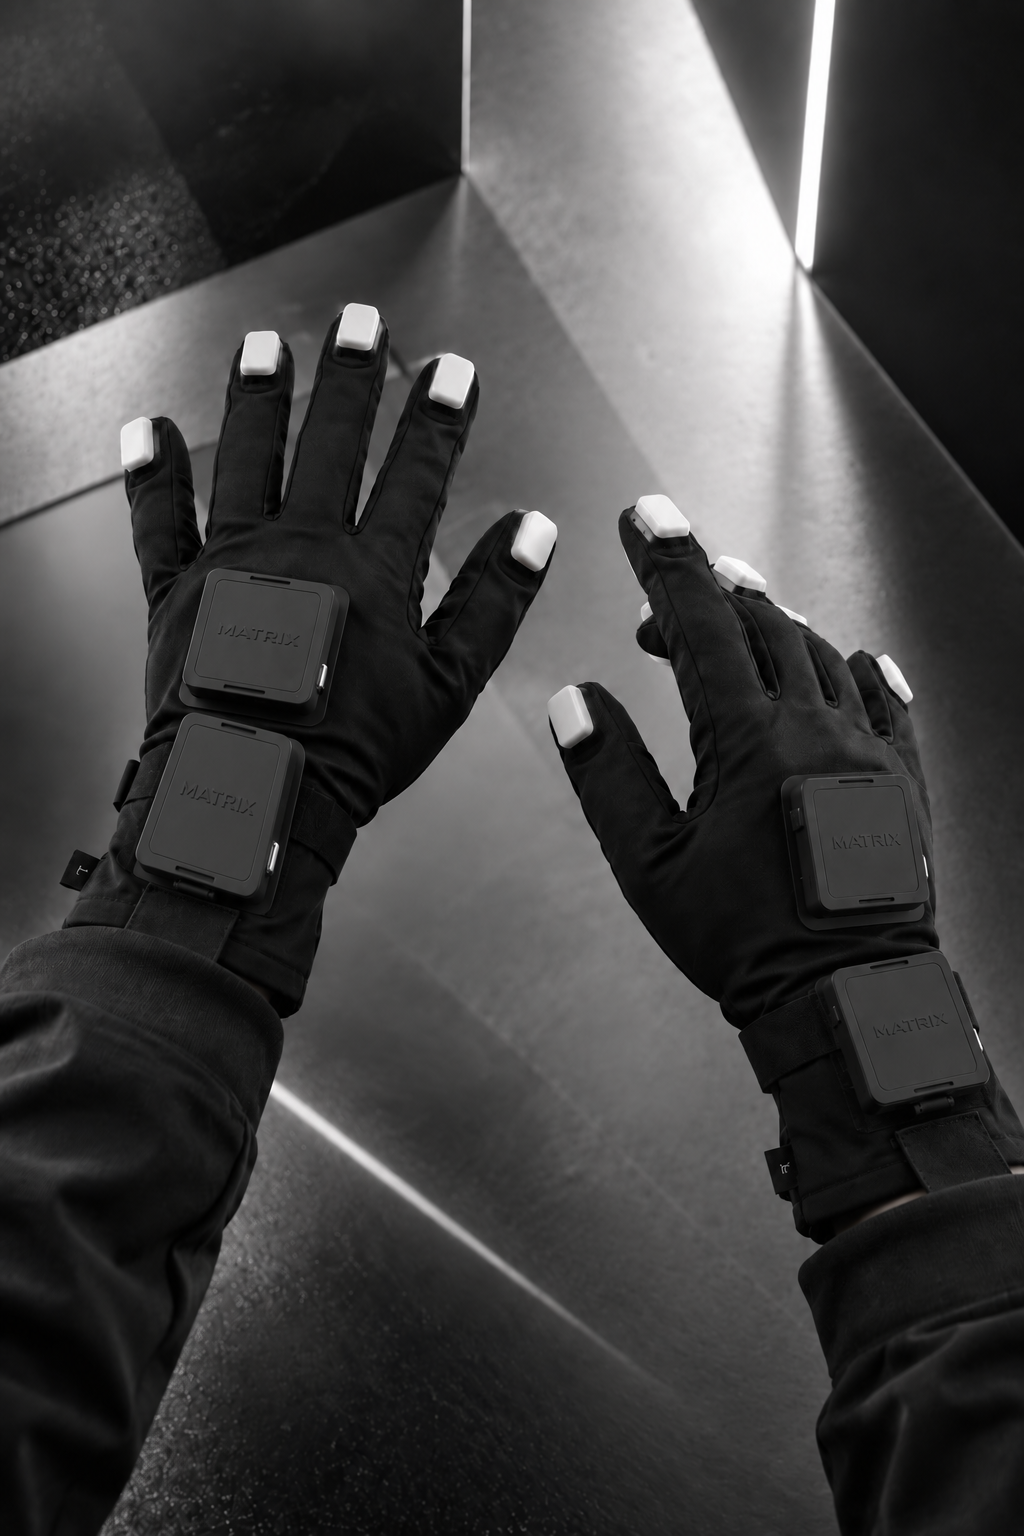 FABRIC TACTILE GLOVE
T-Tex X1 + EMF
360 sensing points · 9 pts/cm² · 20 g trigger · 1500 g max · 120 Hz
View product →
C-Film S1 + EMF
A tactile sensing device built on flexible printed circuit (FPC) pressure sensors on a fabric substrate, fused with a high-precision spatial positioning system.
C-Film S1 + EMF
The MOXIAN FPC tactile data-acquisition glove is a tactile sensing device built on the integrated technology of flexible printed circuit (FPC) pressure sensors and a fabric substrate. Driven by FPC pressure-sensing units, it converts pressure deformation from hand-object interaction into electrical signals, enabling real-time collection of tactile pressure data over the key contact areas of the hand.
Localized rigid support structures are added to the sensing areas at the fingertips, finger pads, and palm, providing a stable mounting base for the FPC sensors. Together, the outer fabric liner and the sensing units form a stable force-transmission interface that ensures reliable pressure-signal acquisition.
High-Density High-Res Tactile Sensing
842 sensing points across the whole hand with 2 mm spatial resolution, covering the main contact areas of fingers and palm for finer, more complete hand pressure distribution.
Low Trigger Force · Wide Measurement Range
Trigger force as low as 0.1 N with a 0–20 N range, covering everything from light contact to firm grasping across a wider span of tactile pressure variation.
Highly Stable Pressure Sensing
Localized rigid supports behind the FPC sensors form a liner – support – FPC – outer-shell composite structure, creating relatively independent force-sensing units that effectively reduce interference from fabric stretching, wrinkling, and finger flexion.
Low Noise · High Signal-to-Noise Ratio
FPC sensing areas respond primarily to effective contact pressure from external objects, significantly reducing noise caused by non-target fabric deformation; valid readings reach 50–100× the noise level.
Integrated Pose × Tactile Sensing
Each glove integrates a spatial positioning module that captures the 3D position and orientation (6-DOF) of each fingertip and the whole hand in real time — pose and tactile data in one hand.
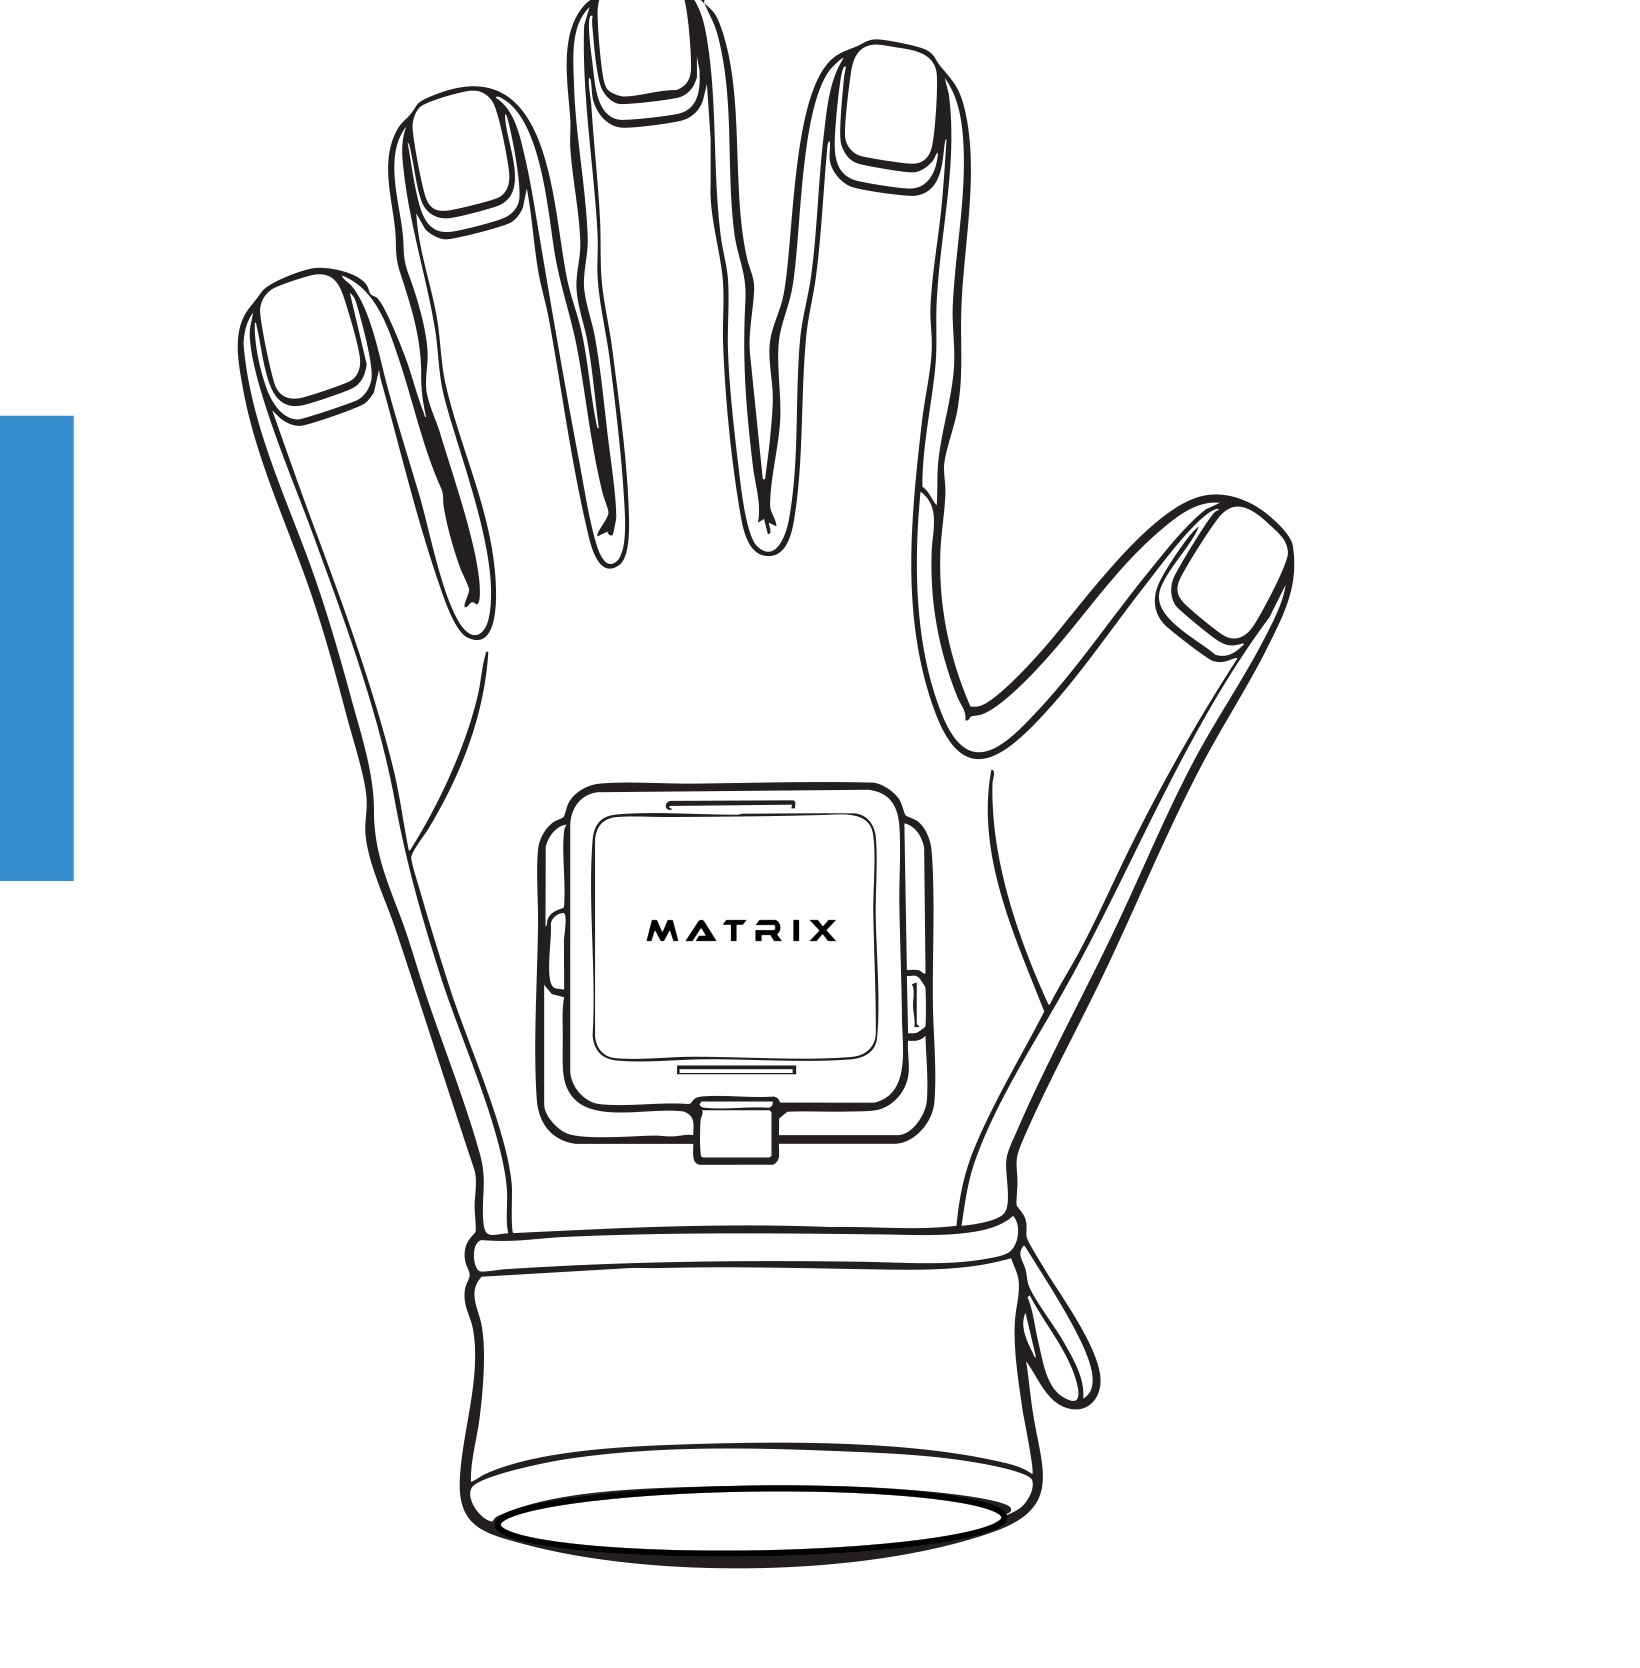
EMF Pose Sensing · Five Core Features
Spatial Positioning · Pose Tracking · Motion Capture — High-Quality Hand Data Acquisition
0.2 mm fingertip accuracy, 6-DOF per fingertip
Each fingertip supports 6-DOF spatial position and orientation tracking with 0.2 mm positioning accuracy, accurately capturing subtle finger movements. It provides a reliable data foundation for fine manipulation, motion analysis, and high-quality pose data collection, faithfully reproducing real hand trajectories and improving the precision and usability of motion data.
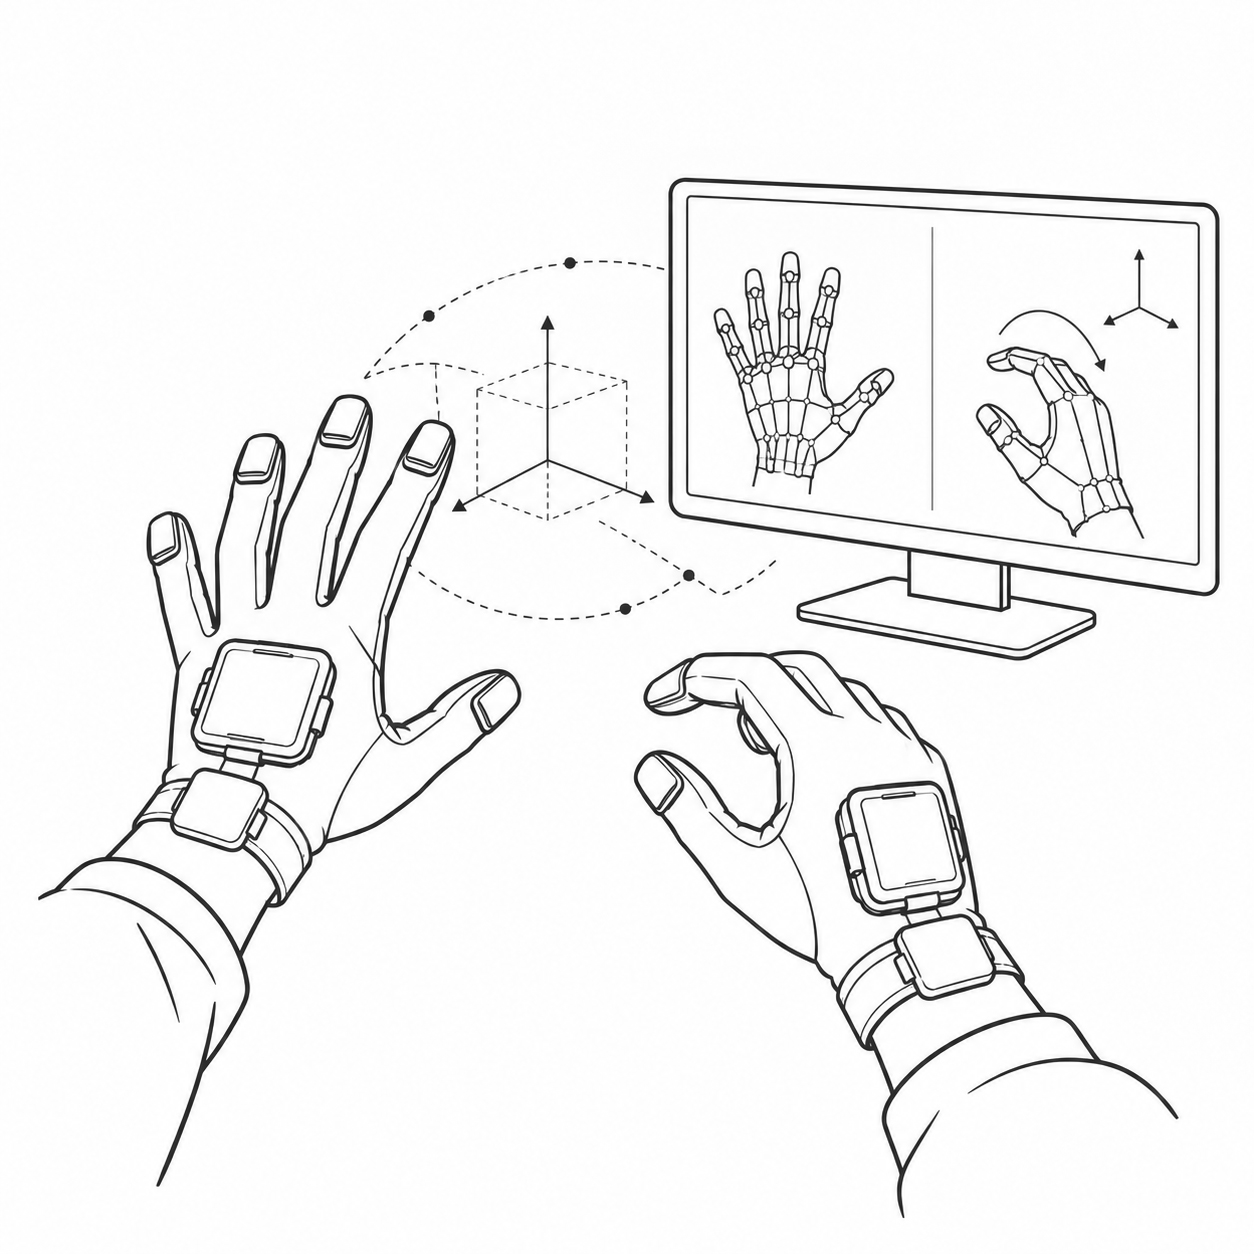
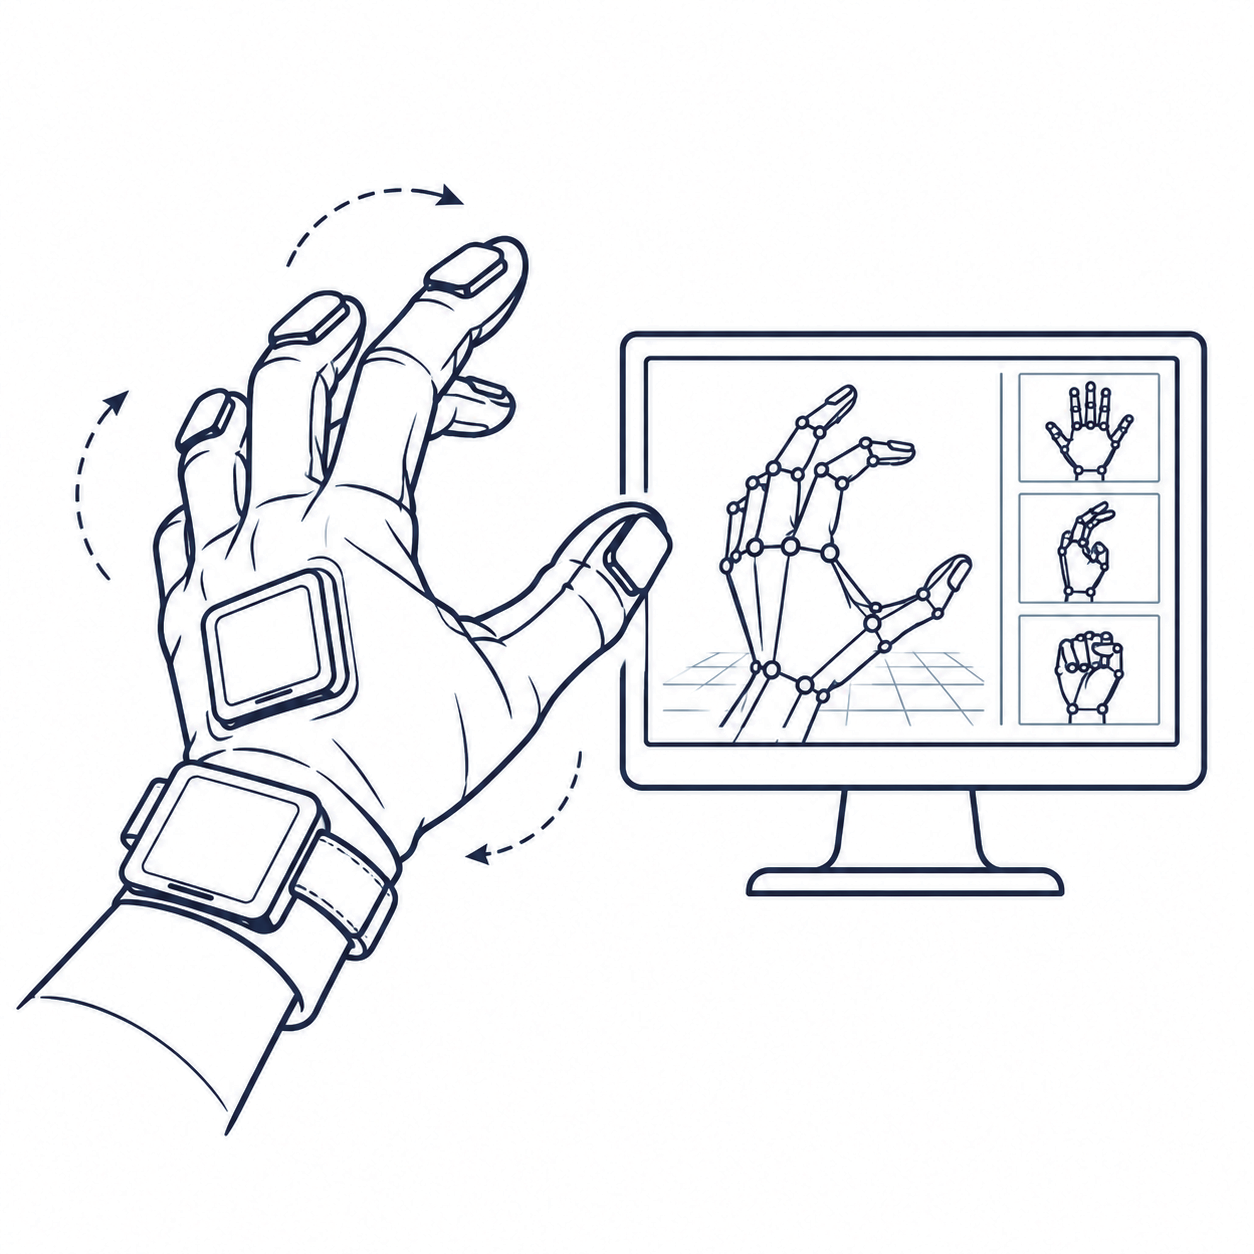
25-DOF whole-hand pose from just 5 sensors
With only 5 VetraSense sensors, the glove achieves whole-hand 25-DOF pose reconstruction, capturing the 3D position and rotation of all five fingers. Complete hand motion capture with fewer sensors provides full spatial pose information for complex gesture recognition, dexterous manipulation, and robot motion mapping.
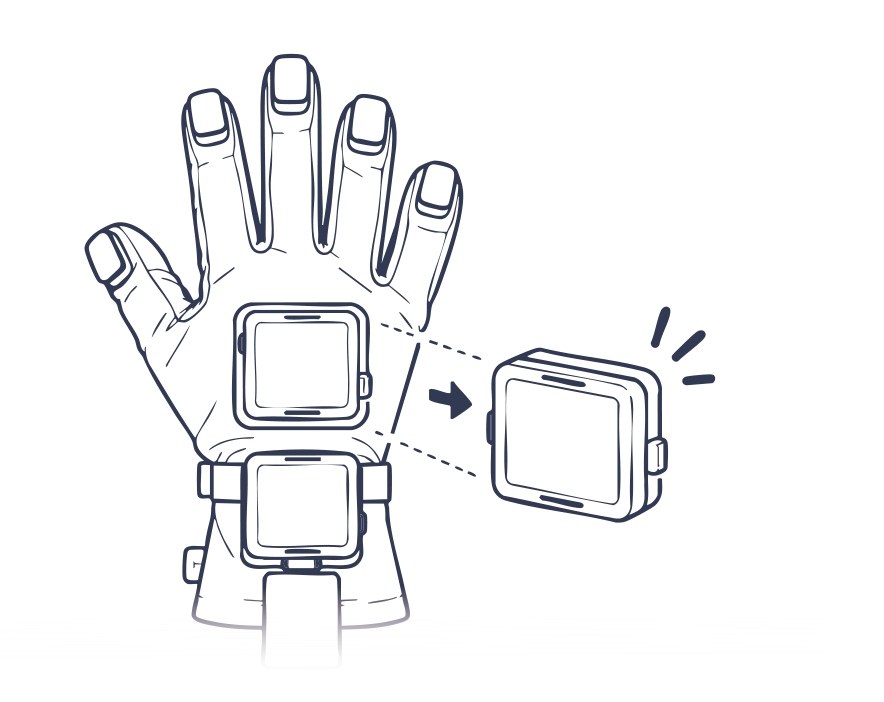
Detachable core module, replace only the glove body
The spatial positioning and data acquisition module on the back of the hand features a detachable modular design that separates quickly from the tactile glove body. When the glove wears out or its tactile parts are damaged after long-term use, only the glove body needs to be replaced while the core module stays in service. The quick-release design also simplifies maintenance, functional upgrades, and glove iteration, effectively reducing replacement costs and extending the service life of the core module.
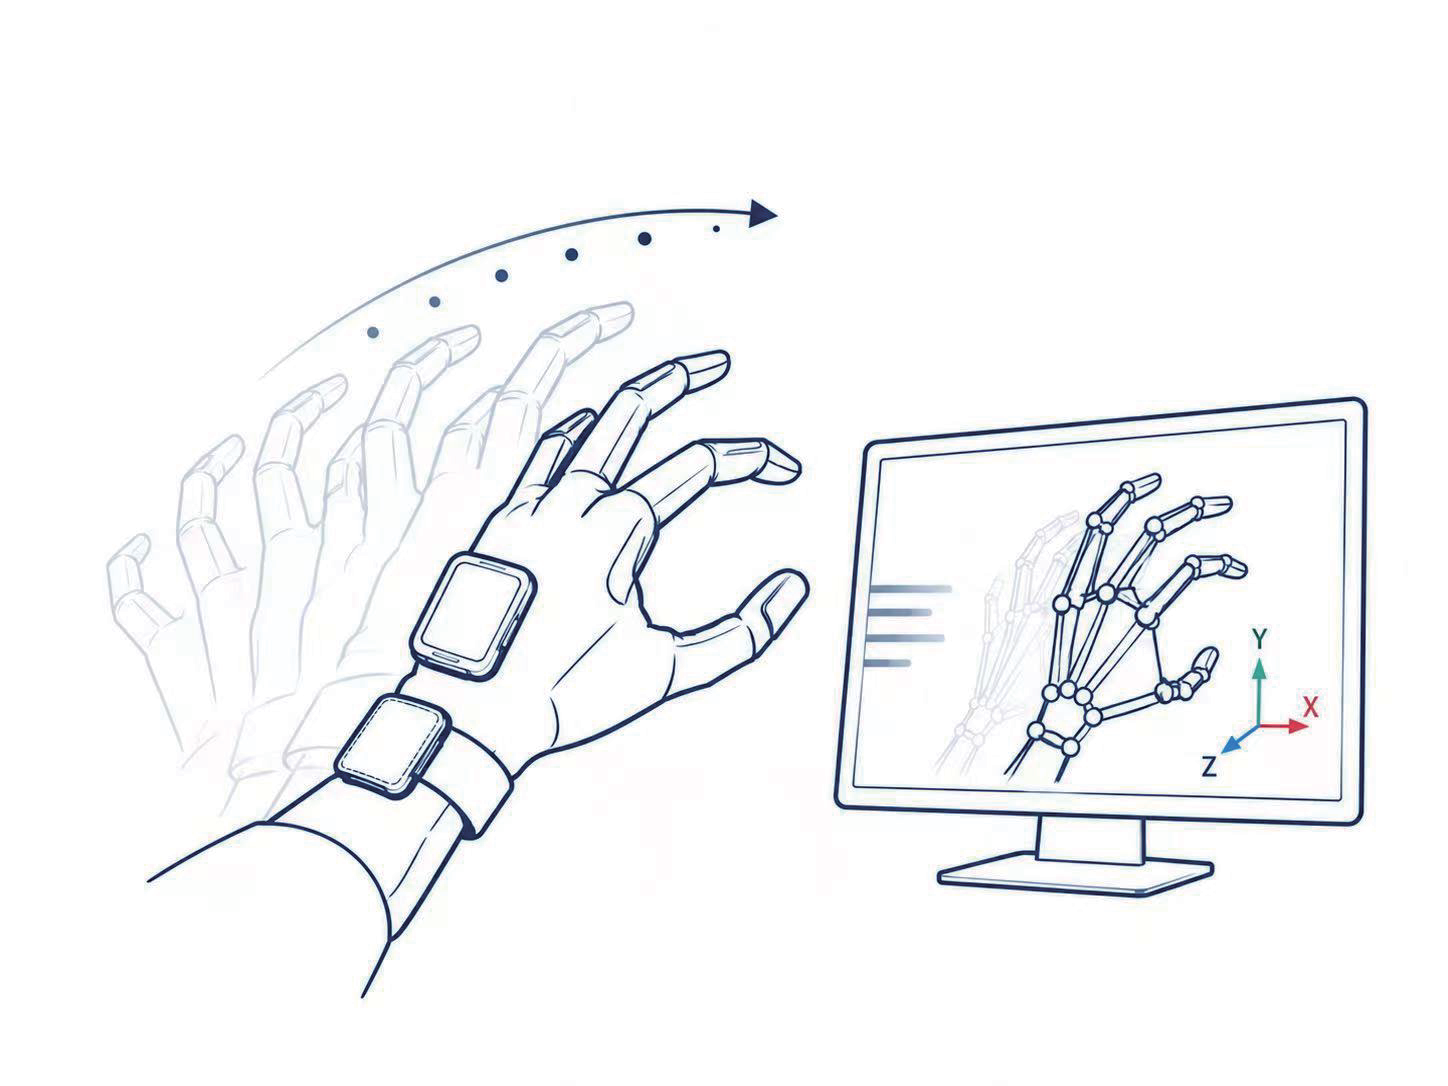
120 Hz sampling, no motion detail lost
With a 120 Hz spatial-position sampling rate, the glove continuously captures fast and subtle hand movements, recording dynamic pose changes more completely. It suits dexterous-manipulation training, teleoperation, and embodied-AI data collection, reducing information loss during rapid motion and providing high-quality data for continuous motion analysis and model training.
≈10 ms wired / ≈30 ms wireless
Wired and wireless pose data transmission are supported, with latency of about 10 ms (wired) and 30 ms (wireless). Hand motion is fed back rapidly, meeting applications that demand high motion synchronization such as robot teleoperation and real-time control, reducing motion delay between the operator side and the robot side, and improving real-time performance and tracking fidelity in teleoperation.
Technical Specifications
T-Tex X1 + EMF
A comfortable, close-fitting fabric glove that turns pressure into electrical signals through percolative-material sensors, fused with a high-precision spatial positioning system.
T-Tex X1 + EMF
The MOXIAN tactile data-acquisition glove integrates fabric pressure sensors based on percolative materials with a high-precision spatial positioning system. Pressure applied to the glove’s fabric sensing areas is converted into changes in electrical resistance, yielding pressure-distribution information: the greater the pressure, the lower the resistance.
Its piezoresistive behavior follows a power-law relationship between resistance and pressure, with the reciprocal of resistance approximately linear with pressure. Meanwhile, the glove integrates a high-precision spatial positioning module that captures the 3D position and orientation (6-DOF) of each finger and the whole hand in real time.
High-Density Tactile Sensing
360 sensing points are evenly distributed across the glove’s pressure-sensing areas, with trigger force as low as 20 g and a measurement range up to 1500 g, accurately capturing the complete pressure variation from light contact to firm grasping.
High-Fidelity Hand Tactile Perception
The fabric glove delivers high-fidelity tactile feedback when worn, deforming in sync with grasping motions to ensure gripping stability and control precision.
Soft, Skin-Friendly and Close-Fitting
The soft, form-fitting fabric offers a comfortable wearing experience, and the glove can be customized to the user’s hand size to fit different hand shapes.
Integrated Pose × Tactile Sensing
Each glove integrates a spatial positioning module that captures the 3D position and orientation (6-DOF) of each finger and the whole hand in real time.
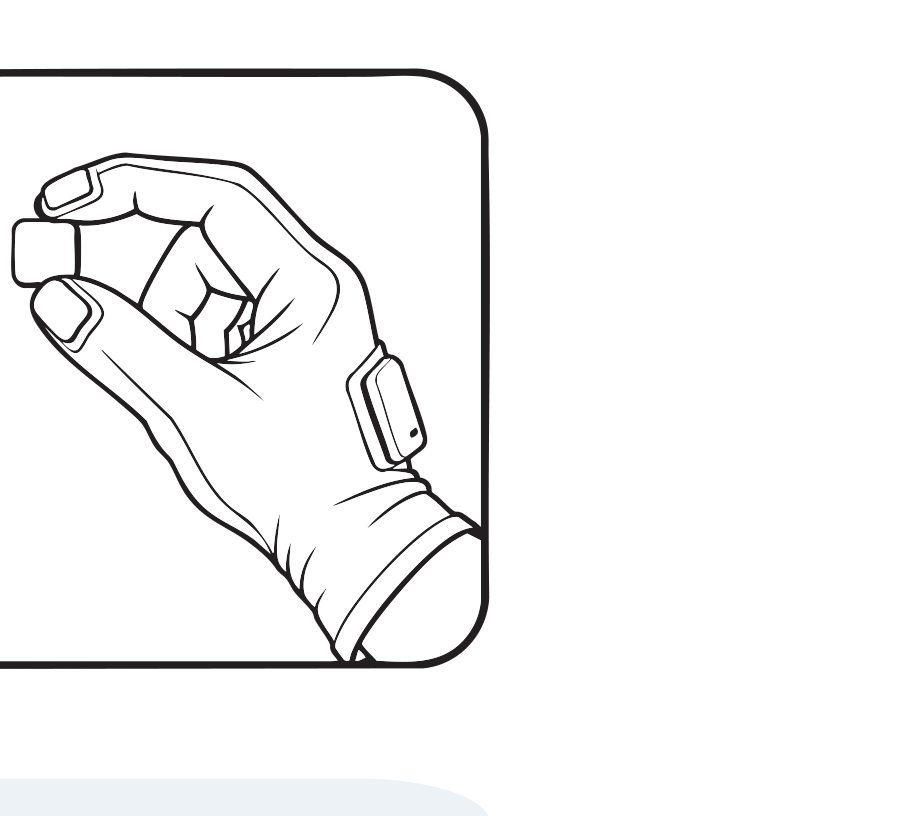
Precision Pinch & Grasp Feedback
Fingertip sensing areas capture pinch and grasp interactions with high fidelity — thumb–index pinch, object manipulation, and contact pressure variation are recorded for precise manipulation research.
EMF Pose Sensing · Five Core Features
Spatial Positioning · Pose Tracking · Motion Capture — High-Quality Hand Data Acquisition
0.2 mm fingertip accuracy, 6-DOF per fingertip
Each fingertip supports 6-DOF spatial position and orientation tracking with 0.2 mm positioning accuracy, accurately capturing subtle finger movements. It provides a reliable data foundation for fine manipulation, motion analysis, and high-quality pose data collection, faithfully reproducing real hand trajectories and improving the precision and usability of motion data.
25-DOF whole-hand pose from just 5 sensors
With only 5 VetraSense sensors, the glove achieves whole-hand 25-DOF pose reconstruction, capturing the 3D position and rotation of all five fingers. Complete hand motion capture with fewer sensors provides full spatial pose information for complex gesture recognition, dexterous manipulation, and robot motion mapping.
Detachable core module, replace only the glove body
The spatial positioning and data acquisition module on the back of the hand features a detachable modular design that separates quickly from the tactile glove body. When the glove wears out or its tactile parts are damaged after long-term use, only the glove body needs to be replaced while the core module stays in service. The quick-release design also simplifies maintenance, functional upgrades, and glove iteration, effectively reducing replacement costs and extending the service life of the core module.
120 Hz sampling, no motion detail lost
With a 120 Hz spatial-position sampling rate, the glove continuously captures fast and subtle hand movements, recording dynamic pose changes more completely. It suits dexterous-manipulation training, teleoperation, and embodied-AI data collection, reducing information loss during rapid motion and providing high-quality data for continuous motion analysis and model training.
≈8 ms wired / ≈30 ms wireless
Wired and wireless pose data transmission are supported, with latency of about 8 ms (wired) and 30 ms (wireless). Hand motion is fed back rapidly, meeting applications that demand high motion synchronization such as robot teleoperation and real-time control, reducing motion delay between the operator side and the robot side, and improving real-time performance and tracking fidelity in teleoperation.